All-Terrain Autonomous Navigation Vehicle
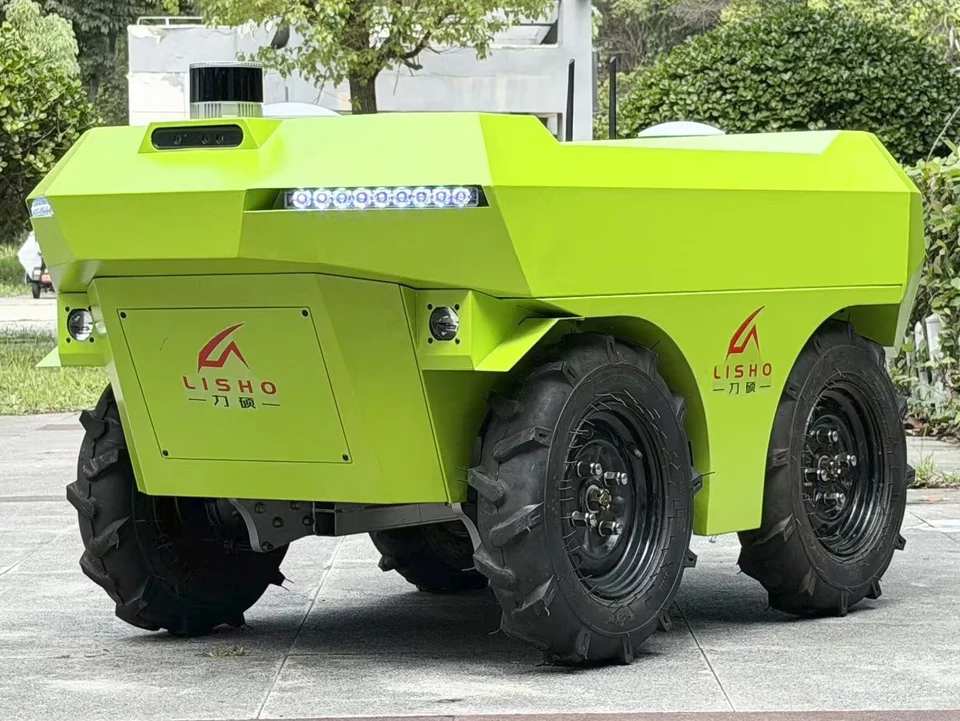
Pangolin AT-1
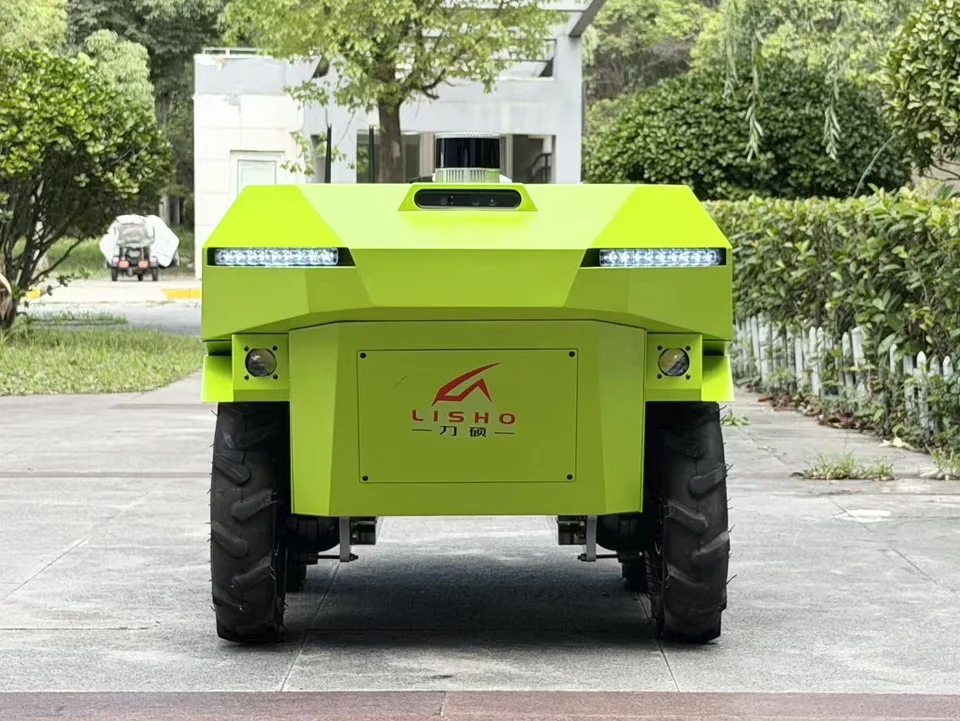
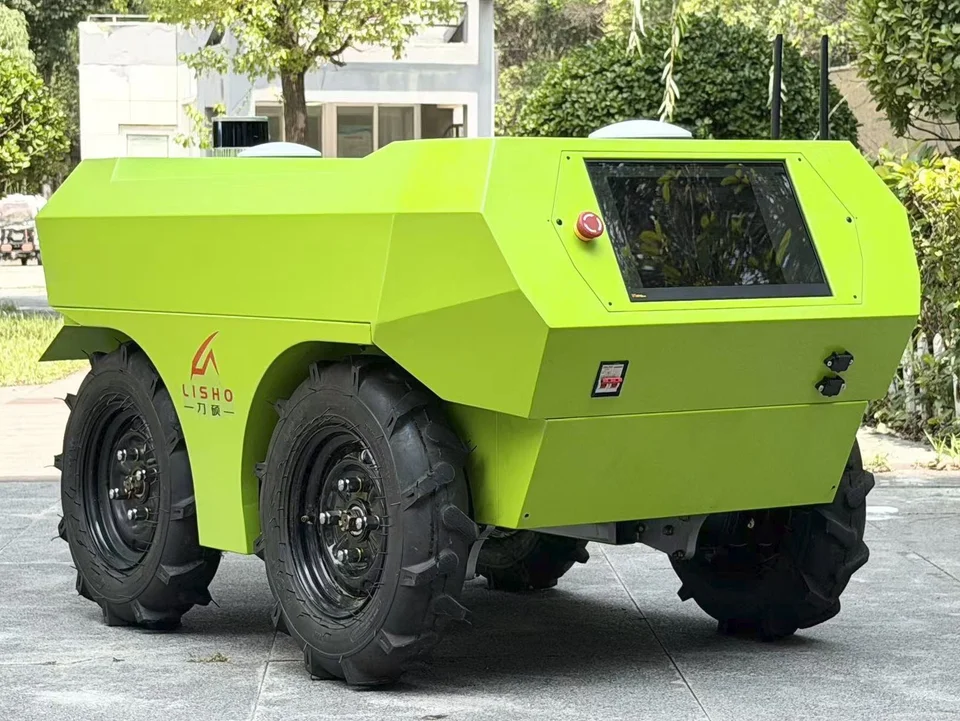
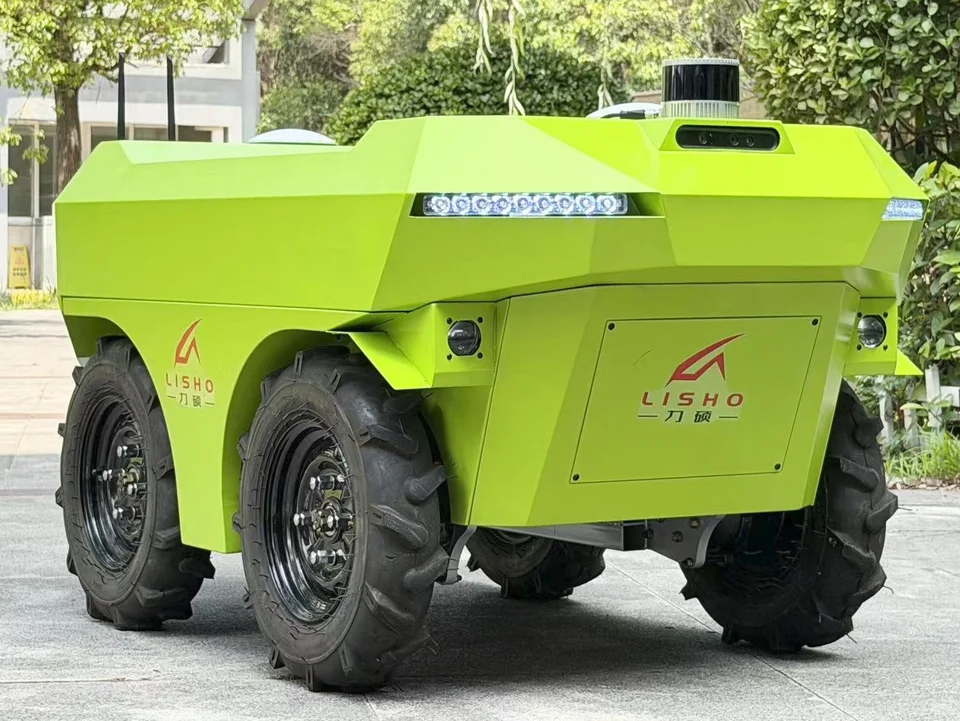
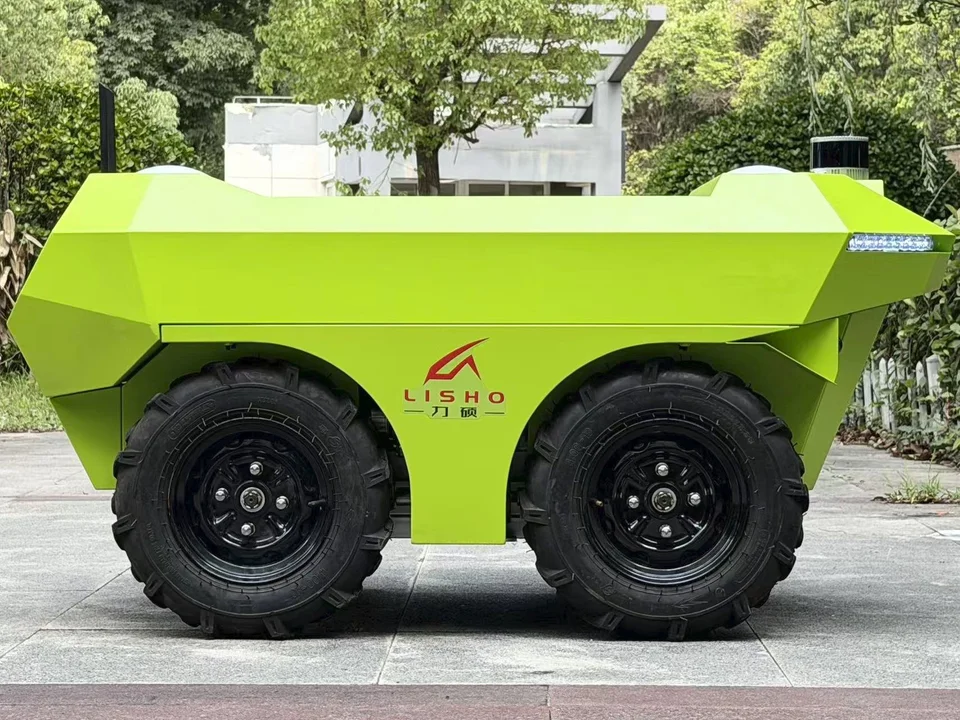
A low-speed unmanned work platform built for PV, agriculture, campuses, construction sites, and complex outdoor environments. It combines LISHO's self-developed floating suspension and differential-steering chassis with RTK, 3D LiDAR, and an autonomous navigation system to enable autonomous transport, route following, obstacle avoidance, and remote operations across challenging terrain.
All-Terrain
Floating Suspension
Drive Type
4WD + Shaft Drive
Obstacle Clearance
15Cm vertical obstacles
Communication
RF / Wi-Fi / 4G / 5G / Satellite
Control Mode
Mobile App
Popular Modifications
High-Pressure Water Gun / Disinfection Spray
Product Overview
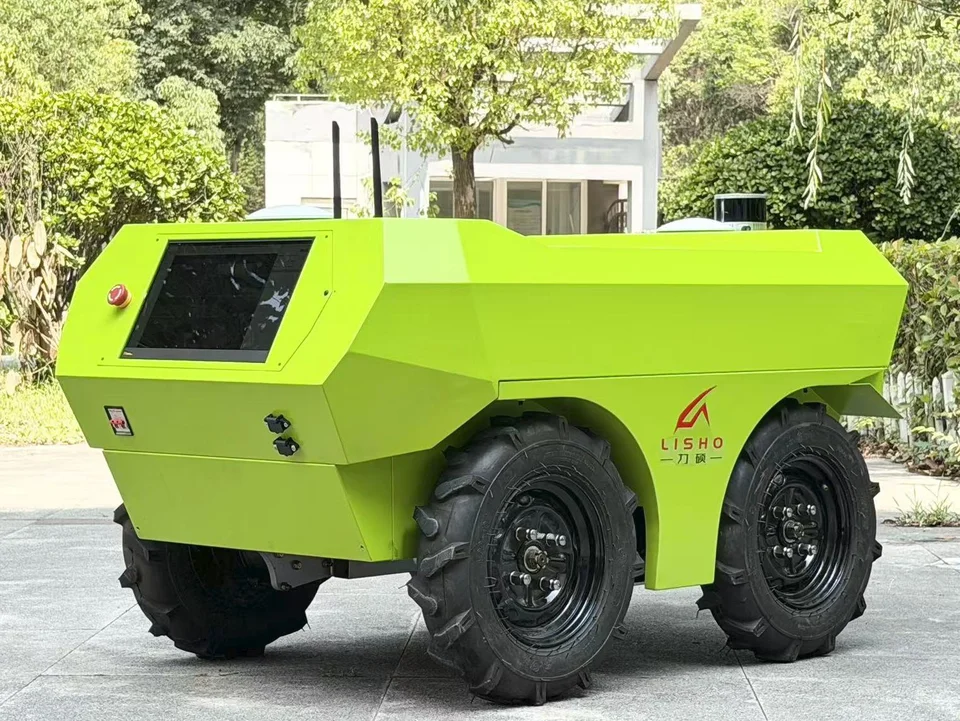
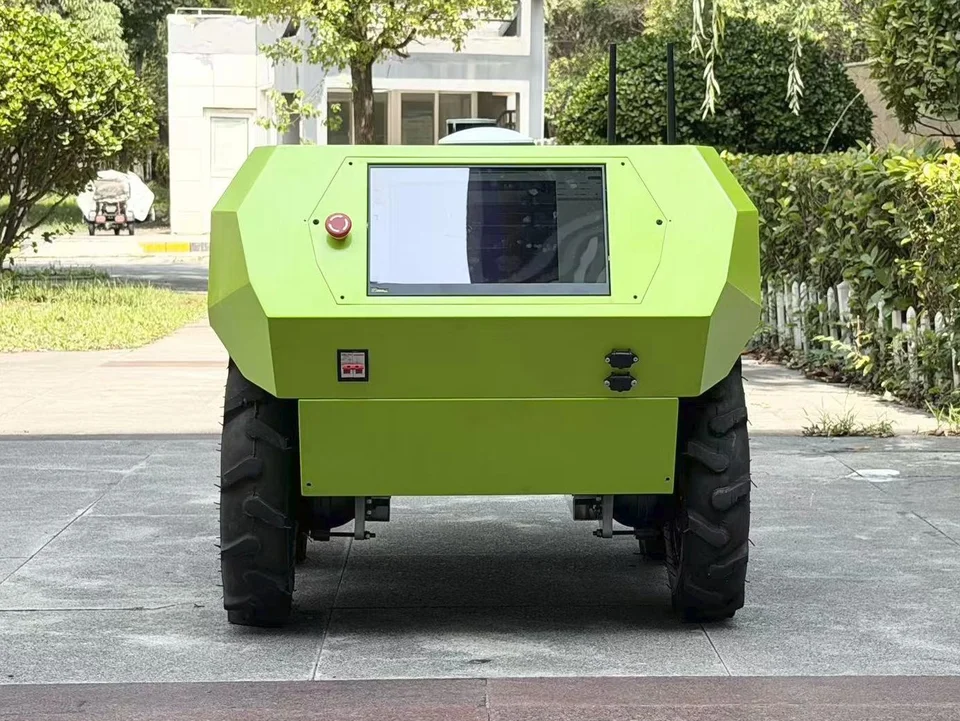
The Pangolin AT-1 is an all-terrain autonomous navigation vehicle developed by Xuzhou LISHO Robotics for complex outdoor operations. Built on the LISHO G 480 drive-by-wire chassis, it combines a self-developed floating suspension, 4WD, and differential steering to balance difficult-terrain mobility with maneuverability in confined spaces. The chassis integrates RTK, 3D LiDAR, depth cameras, and LISHO's self-developed LishoPilot autonomous navigation system. Depending on the environment, it can use RTK positioning or LiDAR SLAM navigation for autonomous navigation, route planning, autonomous obstacle avoidance, and route following. Users can remotely control the vehicle, plan tasks, and monitor operation through a desktop app or mobile app, with support for unified multi-vehicle dispatch. With standardized electrical interfaces, CAN / RS 485 / LAN communication, and a ROS 2 SDK, the vehicle can be equipped with professional work systems such as transport modules, inspection equipment, cleaning devices, and robotic arms to meet customized unmanned operation requirements.
- LISHO patented product
- All-terrain autonomous navigation vehicle
- Drive-by-wire chassis
- 4WD
Specifications
General Specifications
| Parameter | Specification | Notes |
|---|---|---|
| Model | Pangolin AT-1 | |
| Dimensions (L × W × H) | 160 x 85 x 91 (Cm) | |
| Curb Weight | 350Kg | Standard configuration |
| Rated Payload | 300Kg | |
| Control Mode | Remote controller, Windows / Linux / app | |
| Communication Range | Network communication; not limited by the range of a traditional remote controller |
Chassis Performance
| Parameter | Specification | Notes |
|---|---|---|
| Drive Type | 4WD | Shaft drive; non-chain transmission |
| Suspension | Floating suspension | LISHO patented |
| Steering Type | Differential steering | |
| Braking | FOC vector control + physical parking brake | Power-off braking with secondary protection |
| Tire Size | Diameter: 52 cm; width: 11 cm | 4.00-10 |
| Ground Clearance | 10 Cm | Chassis clearance from the ground |
| Track Width | 63 Cm | |
| Minimum Turning Radius | 0 m | 360° rotation in place |
| Maximum Obstacle Height | 15 Cm | |
| Maximum Climbing Angle | 30° | |
| Maximum Speed | 10 km/h |
Electrical System
| Parameter | Specification | Notes |
|---|---|---|
| Motor | 800W permanent-magnet synchronous motor | Quantity: 2 |
| Motor Controller | Servo motor controller (<=100A) | Quantity: 2 |
| Vehicle Control Unit | LISHO-developed VCU | Quantity: 1 |
| Battery Type | LiFePO4 battery (new cells) | Jikong BMS protection board |
| Battery Capacity | 100AH | 48V50AH x 2 |
| Rated Operating Voltage | 48V | DC power supply |
| Operating Time | 12 hours | Continuous operating time at rated load |
| Charging | External adapter charging | |
| Charging Time | 6 hours to full charge | |
| Communication | RF / Wi-Fi / 4G / 5G / satellite |
Expansion Interfaces
| Parameter | Specification | Notes |
|---|---|---|
| Power Output | 12/24/48V DC | |
| Communication Interfaces | CAN, RS485, LAN | Open communication protocol |
| SDK | ROS2 driver examples |
Payload Equipment
| Parameter | Specification | Notes |
|---|---|---|
| Depth Camera | 1280x720@30FPS | |
| 3D LiDAR | 16 channels, 150 m range, 1 cm accuracy | |
| RTK Module + Antenna | BDS/GPS/GLONASS/GALILEO |
Navigation & Perception
| Parameter | Specification | Notes |
|---|---|---|
| Outdoor Positioning Accuracy | 1.5 cm | |
| Indoor Positioning Accuracy | 1.0 cm |
Popular Modifications
| Parameter | Specification | Notes |
|---|---|---|
| High-Pressure Water Gun | Water pressure 6 Mpa | |
| Disinfection Spray | 45° spray angle, 5-15 μm atomized particles |
Key Features
All-Terrain Mobility
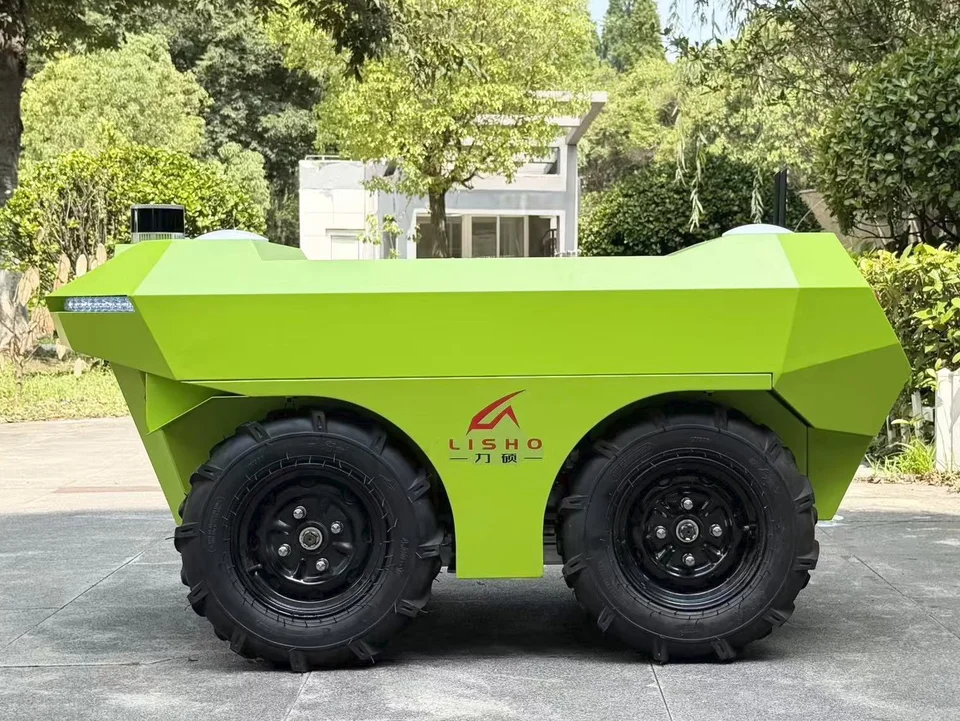
LISHO's self-developed patented floating suspension keeps all four wheels firmly grounded across potholes, undulations, cross-axle terrain, and other complex surfaces, improving mobility and driving stability. The 4WD shaft-drive structure reduces the maintenance and jamming issues associated with traditional chain transmission and is better suited to complex outdoor environments.
Four-Wheel Drive
Two 800 W permanent-magnet synchronous motors independently drive four wheels. Each wheel has independent power output, maximizing multi-wheel traction and obstacle performance under load, on potholes, slopes, and complex surfaces.
Autonomous Navigation
The self-developed LishoPilot autonomous navigation system supports Windows, Linux, and app control as well as multi-vehicle dispatch. It enables route planning, task assignment, real-time status monitoring, and remote takeover. Combined with RTK and 3D LiDAR, it supports autonomous navigation, planning, dynamic obstacle avoidance, and route following over 4G/5G networks.
Open Work Platform
Standardized hardware interfaces and a software SDK support rapid expansion with transport cargo boxes, inspection equipment, PV cleaning systems, robotic arms, and other professional work equipment. Open power, CAN, RS485, and LAN interfaces support mechanical, electrical, and software customization for scenario-specific unmanned operations.
Application Scenarios
PV Operations & Maintenance
Operates in complex solar-plant environments for unmanned inspection, transport, and intelligent cleaning.
Factory Logistics
Automates material transport across factory sites while supporting perimeter security inspection.
Construction Site Transfer
Handles short-distance construction-material transfer across muddy and uneven job sites.
Livestock Inspection
Transports supplies and performs automated, all-weather environmental inspection and monitoring at livestock farms.
Military Exercises
Field reconnaissance, position security, forward material delivery, and simulated confrontation exercises.
Safety Inspection
Power inspection, fire warning, factory security patrol, hazardous-site detection, and tunnel or utility-corridor inspection.
Border Patrol
Routine border patrol, cross-border alerts, terrain surveying, and border material delivery.
Gallery
Related Technologies
Frequently Asked Questions
Can the vehicle navigate without an RTK signal?
The positioning method can be switched to suit the site. In obstructed or enclosed areas without an RTK signal, LiDAR SLAM provides stable autonomous positioning and path planning.
Can it be operated without a traditional remote controller?
Yes. Windows desktop, Linux, and mobile applications provide remote control, task planning, and operation monitoring without a traditional remote controller.
Can one person control multiple vehicles?
Yes. Unified fleet dispatch and task management allow one operator to manage multiple vehicles for convoy operations and coordinated delivery, significantly improving fleet efficiency.
Can we install our own work equipment?
Yes. Standardized mechanical mounting points, general electrical interfaces, and software interfaces support transport bodies, inspection equipment, cleaning systems, robotic arms, and other specialized tools.
Can it integrate with the customer's own system?
Yes. CAN, RS485, and LAN protocols plus the ROS 2 SDK support integration with customer control platforms for secondary development and deep customization.
What happens if the vehicle encounters an abnormal condition?
The vehicle supports real-time remote status monitoring, proactive fault warnings, and fault-code feedback. An operator can take over with one action, while onboard self-check functions help locate faults quickly.
What autonomous functions does the vehicle support?
The self-developed LishoPilot system provides autonomous navigation, global path planning, dynamic obstacle avoidance, and fixed-route following for end-to-end unmanned operation.
Which operating scenarios is it designed for?
It is designed for complex outdoor applications including PV-site operations, agricultural field work, campus security inspection, and construction-site material transport, and supports routine autonomous operations.
Want to See How the AT-1 Fits Your Scenario?
Contact the LISHO team for product materials, configuration, and customization support.